NVIDIA open-sources OSMO to orchestrate physical AI training and robot testing
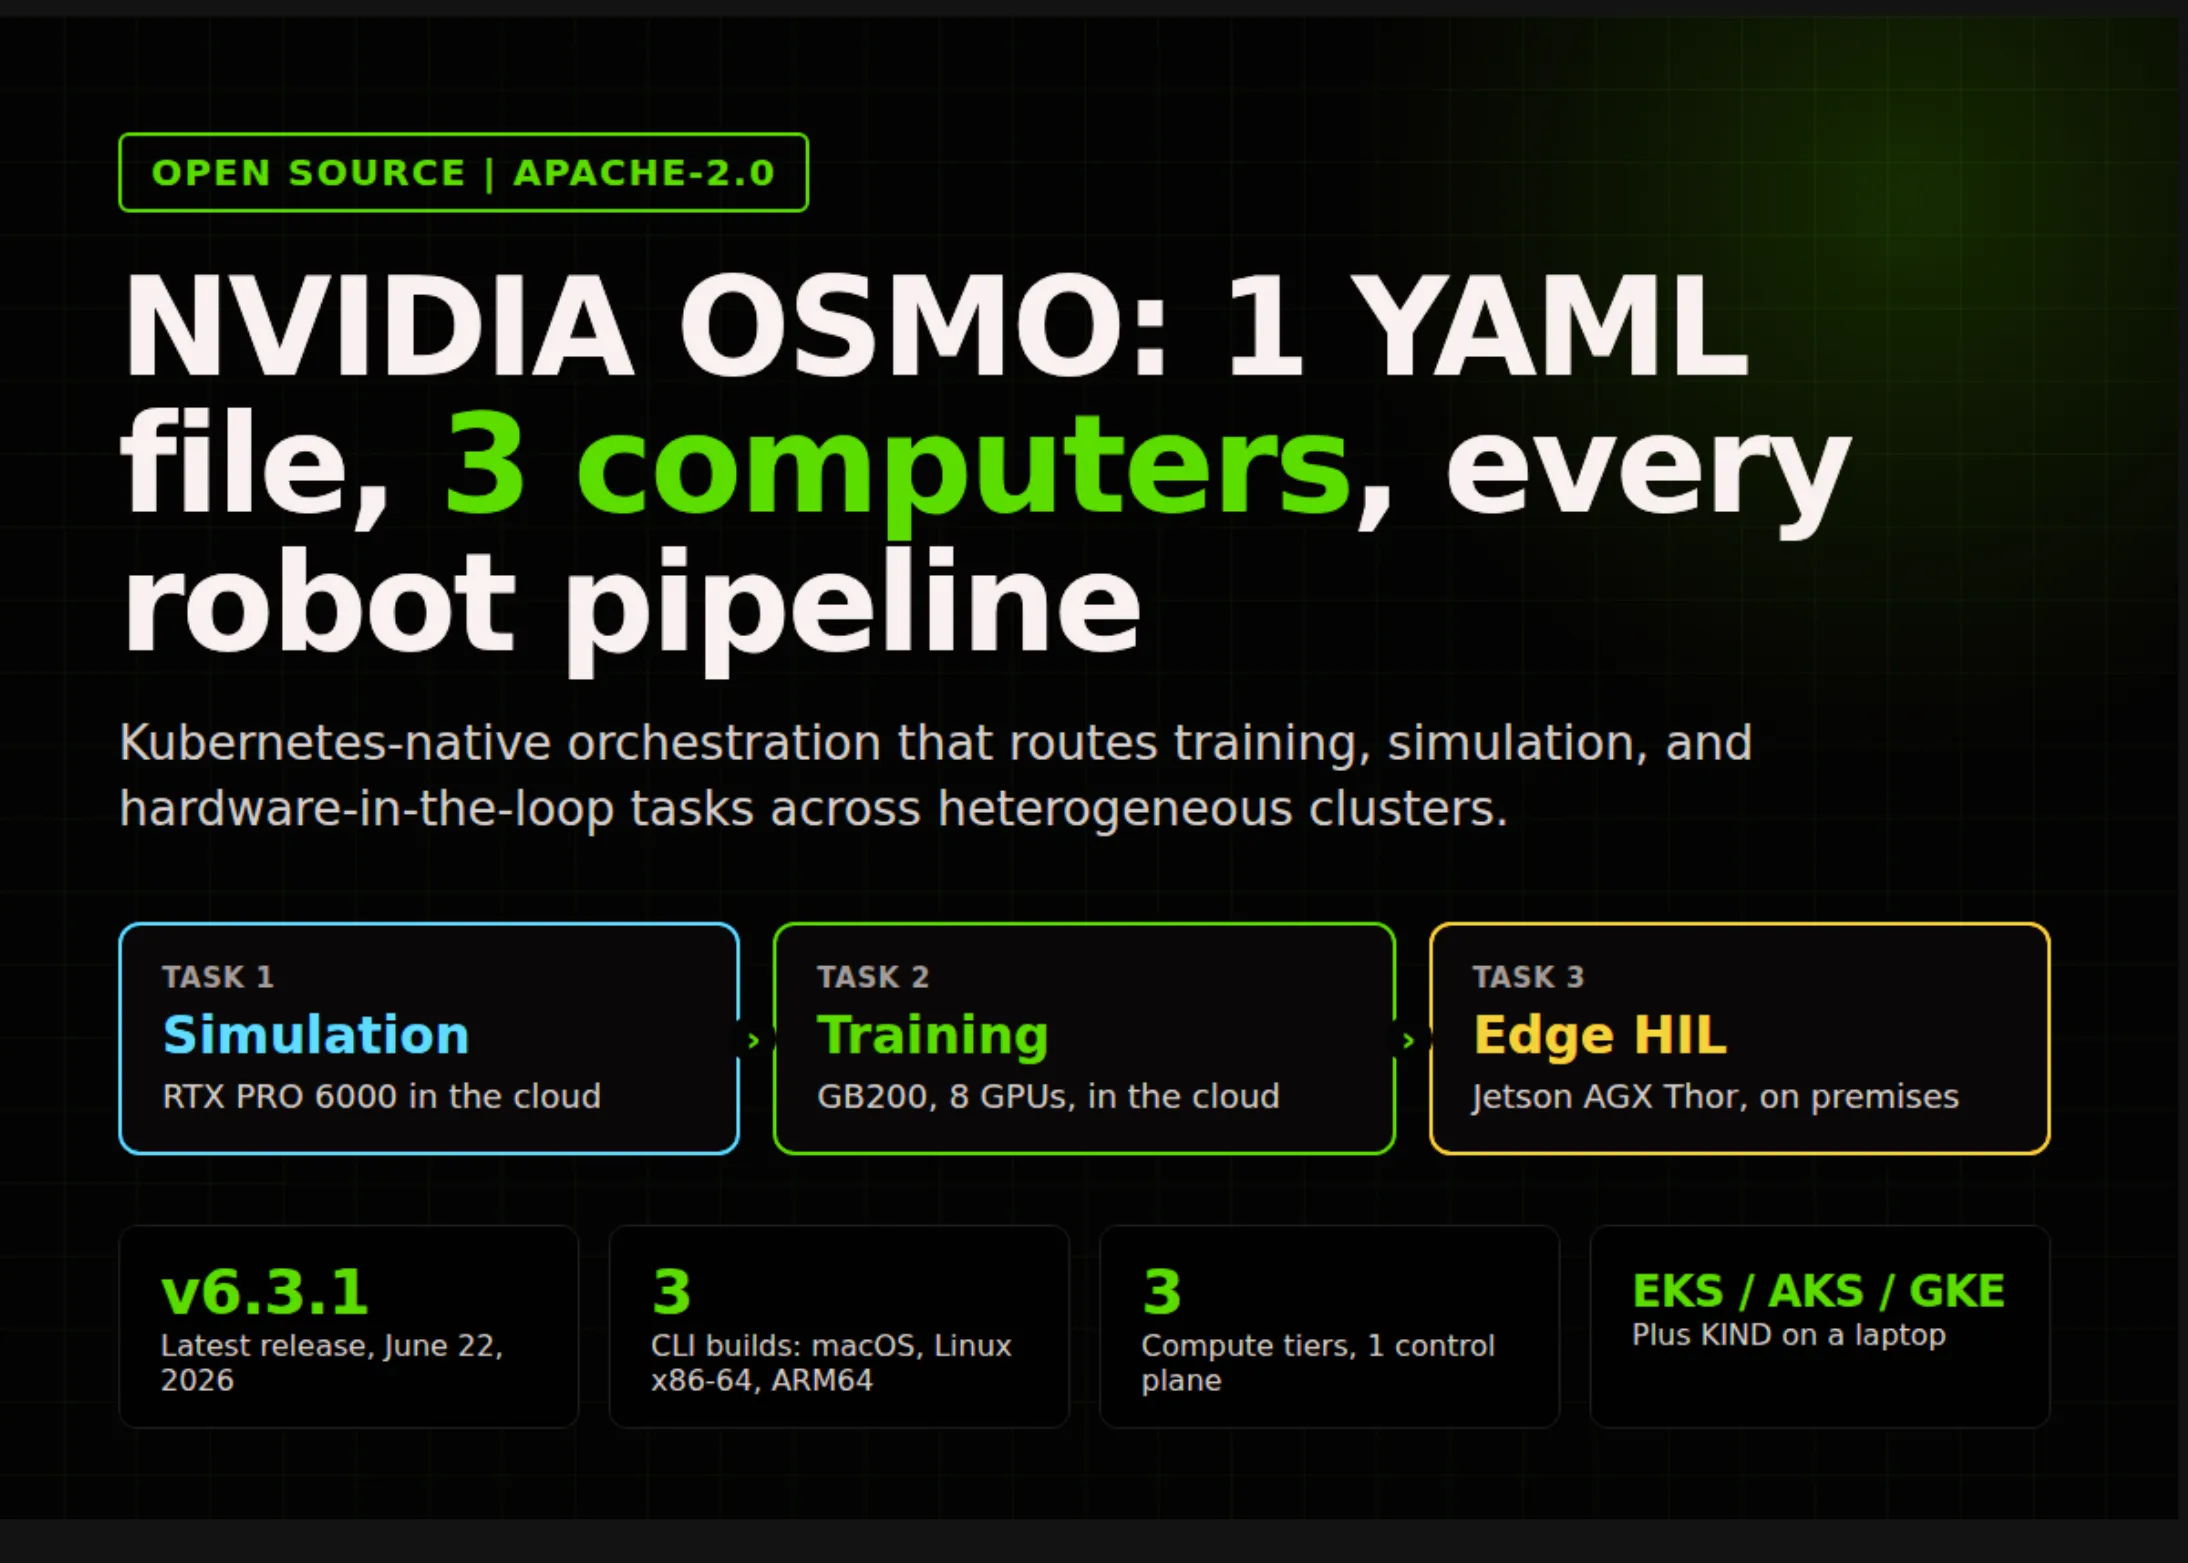
OSMO uses a single YAML file to coordinate three compute tiers: policy training on GB200 or H100 clusters, testing in Isaac Sim on RTX GPUs, and validation on a Jetson inside a real robot. Each tier previously needed its own cluster, scheduler, and glue scripts.
1 source
More stories today
ChatGPT-Image-2.5 added to Nous Portal for Hermes Agent
Teknium·2 hours ago
South Korea's Sovereign AI project names Artificial Analysis evaluator
Artificial Analysis·2 hours ago
Sam Altman and Dario Amodei to speak at Dreamforce
Kimmonismus·2 hours ago
Muse AI app gains iOS dock integration
Alexandr Wang·2 hours ago
Lina Khan: no AI exemption from existing product liability laws
Lina Khan·2 hours agoCreator automates ComfyUI ad pipeline via Claude Code and MCP
A Reddit user in Lima, Peru is driving an entire ComfyUI pipeline through Claude Code using MCP to generate local ad concepts, with Z-Image Turbo as the base reference model. The goal is a less "plasticky," more organic look.
r/ComfyUI·2 hours ago
ComfyUI MiniMax H3 prompt builder adds RefMods editing
A community ComfyUI node for building MiniMax H3 prompts gets a RefMods update for easier creation and editing. The builder is manual with no LLM connected, and the author describes it as vibe-coded.
r/StableDiffusion·2 hours ago
AI bioweapons report divides experts
A report on AI bioweapon risks is drawing both "chilling" warnings and charges of overreaction from experts, per Science. The split centers on how credible the report's threat assessment is.
Hacker News·2 hours ago