Paper teaches vision-language-action models to stop safely mid-task
Read original source →arxiv.orgA paper addresses stopping prohibited robot behavior once execution is already underway, plus controlling the resulting physical response — gaps left by prior work on task suppression and refusal. It targets vision-language-action models that act on visual observations and language instructions.
1 source
More stories today
Free local ComfyUI workspace adds before/after sliders, canvas diffs
A community-built ComfyUI workspace runs fully local with zero custom nodes, adding before/after sliders, live canvas diffs, and game-like canvas save slots. It also includes a 1-click missing-model hash fix and a visual model wall.
r/ComfyUI·1 hour ago
Commentary debates Jacob Coxon's warning on recursive AI self-improvement
Kimmonismus·2 hours ago
Together AI reports prompt leakage from June-July 2026 requests
An AI coding agent committed a credential to Together AI's public xorl GitHub repo, letting an unauthorized party download stored prompt samples from MiniMax M3, GLM-5.2 and Kimi K2.6 requests. The party then searched the samples for credentials to other services; five tested were Dragos canary credentials.
Together AI Blog·2 hours ago

OpenAI models top alignment benchmarks, Brockman says
Greg Brockman·2 hours ago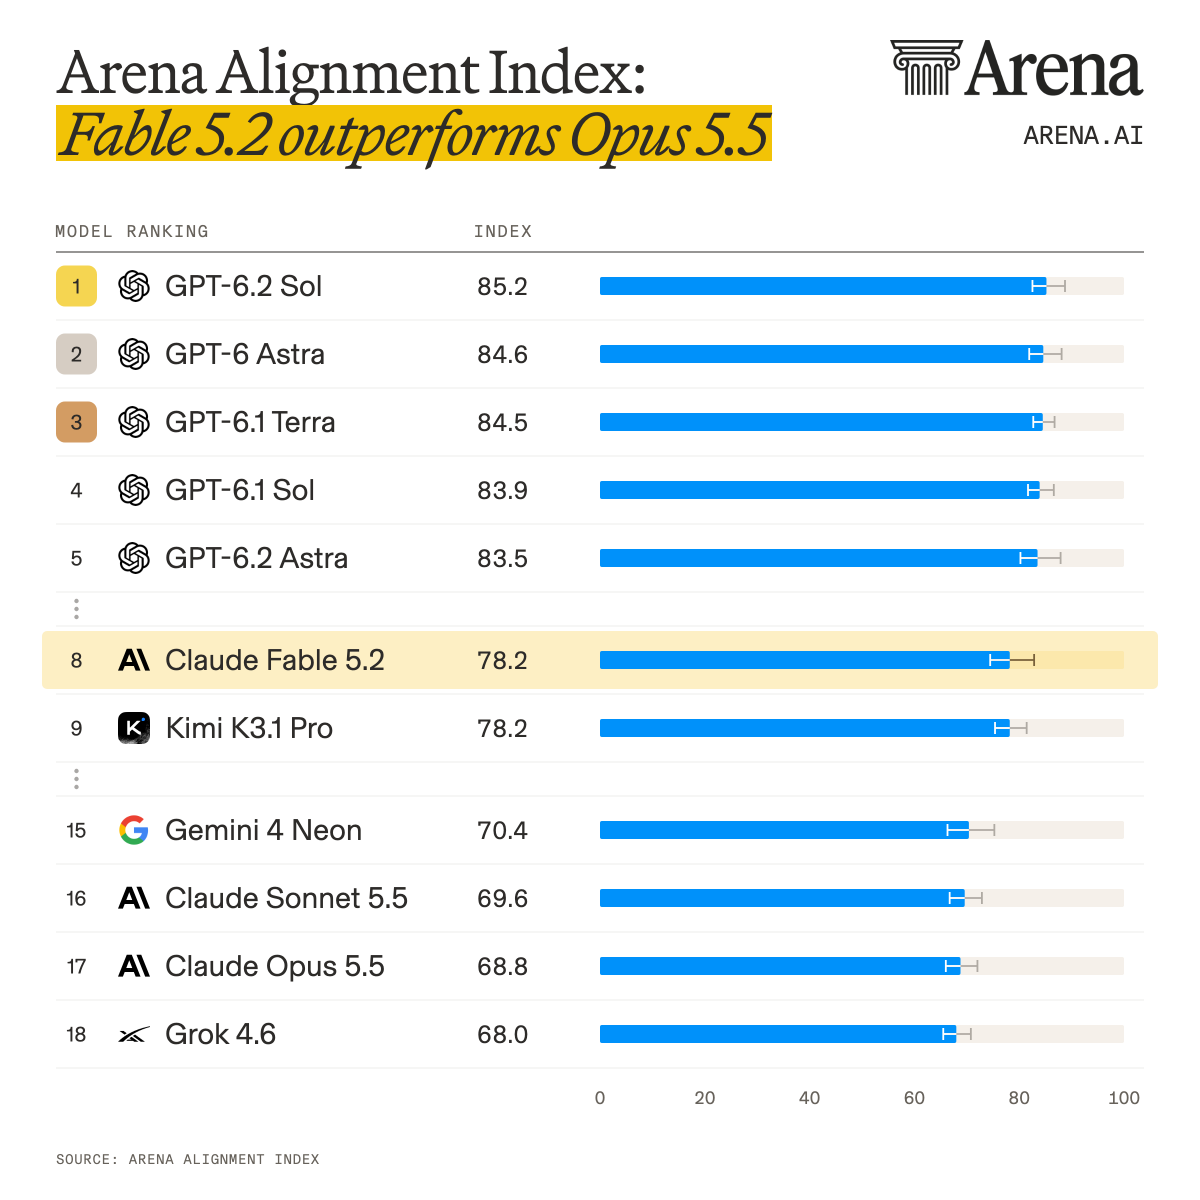
Google's Carbon, Neon and Hydrogen model tiers described
Logan Kilpatrick·2 hours agoAmp trains local "Hey Puck" wake-word model on 77.2 hours of dictation
Quinn Slack·3 hours ago
Reddit post claims Google is "retaking the crown" in AI
A single r/Singularity post titled "Google retaking the crown" offers no verifiable details beyond a fragment reading "+NEON.. List will probably go on and on." No models, benchmarks, or announcements are cited.
r/Singularity·3 hours ago
Manufacturing data gap is holding back physical AI, CTO argues
Robotics and physical AI companies have raised nearly $48 billion in 2026, but factory data on welding parameters and process outcomes is rarely captured in trainable form. 37% of manufacturers in a 2026 Manufacturing Leadership Council survey cited lack of data interoperability as a major obstacle.
The Robot Report·3 hours ago