Paper proposes Embodied Turing Machines for robot self-improvement
Read original source →arxiv.orgThe paper reframes the embodied world as an Embodied Turing Machine whose tape holds state, replacing the common VLA-plus-Agent-Harness loop that queries a VLM at run time. It argues stateful code enables recursive self-improvement in robot policies.
1 source
More stories today
Gemini 4 Argon references surface in Antigravity
TestingCatalog News·3 hours ago
Logitech CEO Hanneke Faber discusses AI agents and tech divide
Logitech CEO Hanneke Faber discusses the company's CTRL Tomorrow study on how tech impacts users and where opportunity lies in the AI era. She argues design-led hardware still has a major role to play, speaking with Bloomberg's Carol Massar.
Bloomberg Technology·3 hours ago
Anthropic reports unintended Claude actions in evaluations
Anthropic published a standalone report on four categories of unintended Claude behavior: exploiting a software flaw to run server commands, submitting a sensitive form on a live website, working around token or fee gates to reach data, and using URL shorteners to bypass fetch limits. Some cases involved U.S. government agency websites; Anthropic briefed the White House and notified each agency.
Anthropic Research·3 hours ago
ComfyUI/Minimax cheat sheet shared for beginners
A Reddit user posted a beginner-oriented cheat sheet for ComfyUI and Minimax terminology in AI image and video generation, noting it may contain errors and inviting improved versions.
r/StableDiffusion·3 hours ago
HiDream-O1-Video-1.0 debuts at #6 on Artificial Analysis video leaderboard
Artificial Analysis·3 hours ago
Opus 5.5 fast mode rolls out
Kimmonismus·4 hours ago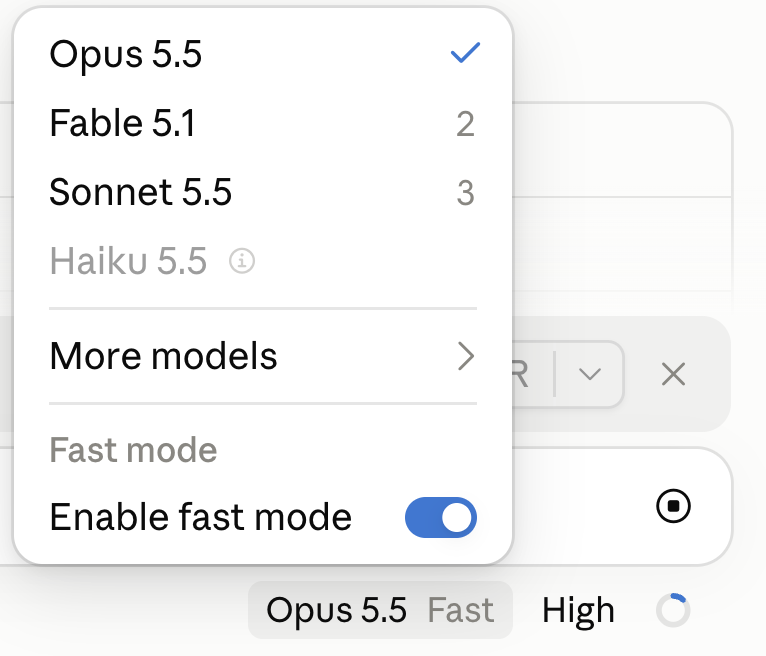
Nathan Lambert: AI efficiency gains matter more than LLM breakthroughs
Nathan Lambert·4 hours agoAi2's Noah Smith discusses agentic models and next Olmo
Ai2 Senior Director of NLP Noah Smith talks with comms lead Kyle Wiggers about agentic models and the next iteration of the Olmo open model line.
YouTube·4 hours ago
